ROS 2 Mobile Robot
A wheeled robot that maps a room in Gazebo as it drives, then navigates to goals on its own. ROS 2 Jazzy with slam_toolbox and Nav2, kept deliberately small.
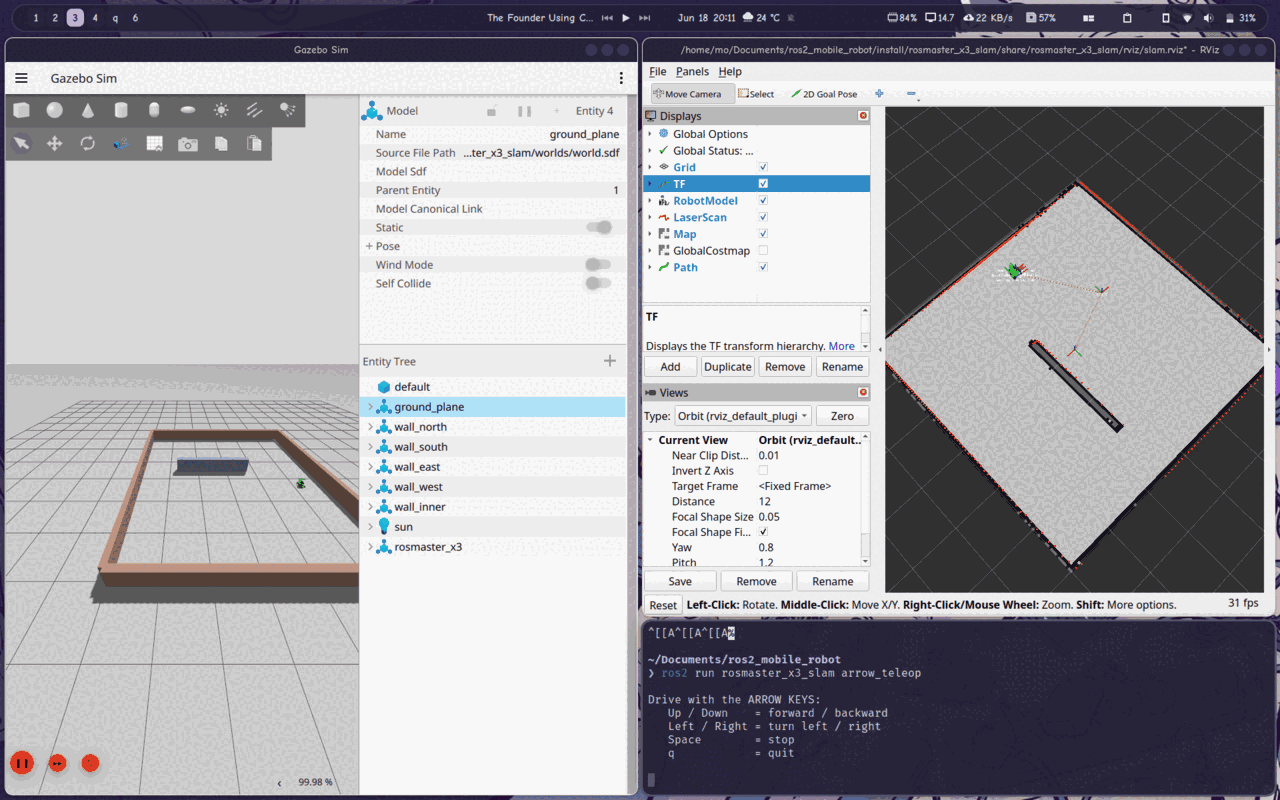
A wheeled robot drives around a room in Gazebo and builds a map as it goes. You steer with the arrow keys, watch the map fill in, and once there’s enough of it you can click a goal in RViz and let the robot drive there on its own. It all runs on ROS 2 Jazzy.
What’s inside
- a simple walled-room world in Gazebo
- a Yahboom ROSMASTER X3 with a 2D lidar
- slam_toolbox handling the mapping
- Nav2 for navigation
- a small Python node for driving with the arrow keys
Kept deliberately small
The whole project is a handful of launch files, a couple of config files, and one short Python node. No C++. One command brings up Gazebo, SLAM, Nav2, and RViz together, and a second terminal runs the teleop node so you can drive. The lidar picks up the walls, the map grows, and when you click a 2D goal pose in RViz, Nav2 plans a path and follows it.